Extra 15% OFF Health & Wellness
Subscribe To Newsletter
Subscribe to the Porto mailing list to receive updates on new arrivals, special offers and our promotions.
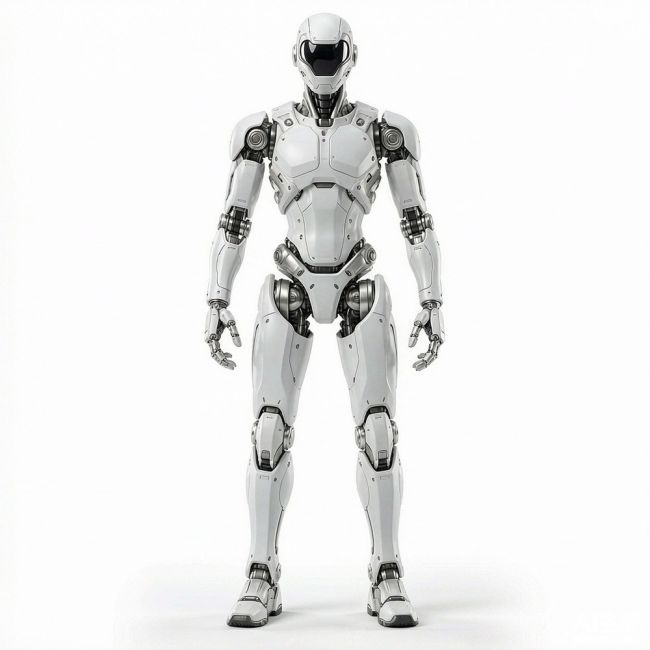
Atlas-H1 is a research-grade bipedal humanoid built for teams that need a real walking platform, not a simulation. Thirty-two harmonic-drive joints deliver smooth, back-drivable motion while the onboard 400 TOPS inference unit runs perception and whole-body control at 200 Hz.
Includes docking station, spare battery, and 12 months of software updates.