Extra 15% OFF Health & Wellness
Subscribe To Newsletter
Subscribe to the Porto mailing list to receive updates on new arrivals, special offers and our promotions.
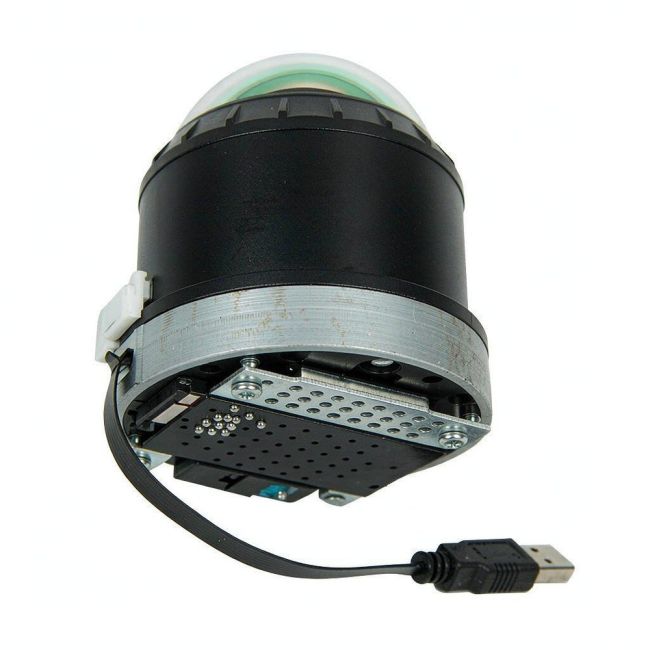
The L1 is the sensor half of a mapping robot. A single rotating ToF head samples 4,500 points per rotation at 10 Hz, and the USB-C interface presents a plain serial stream that works with ROS 2, Python and Arduino.